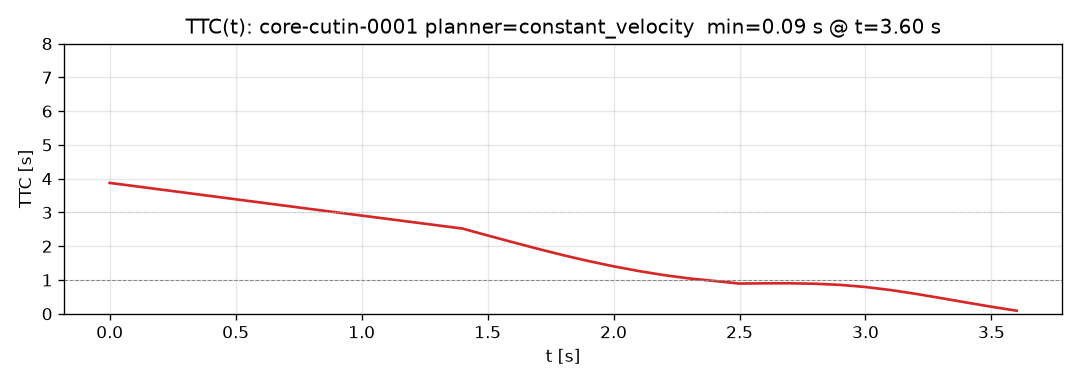
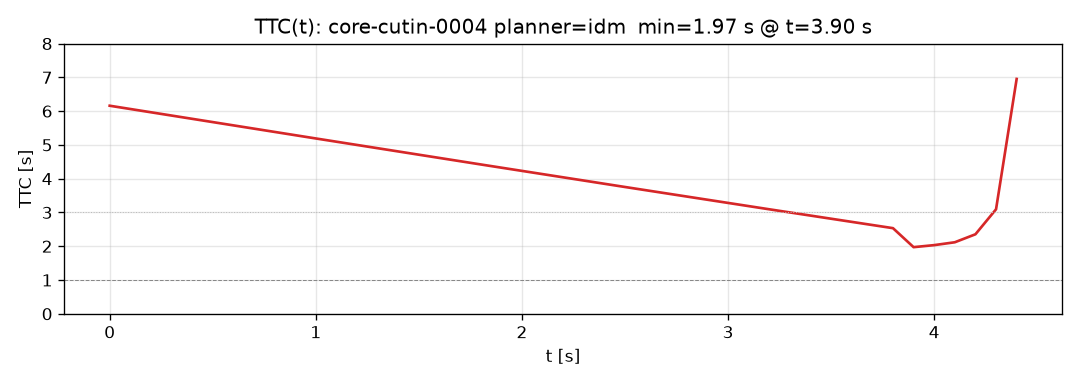
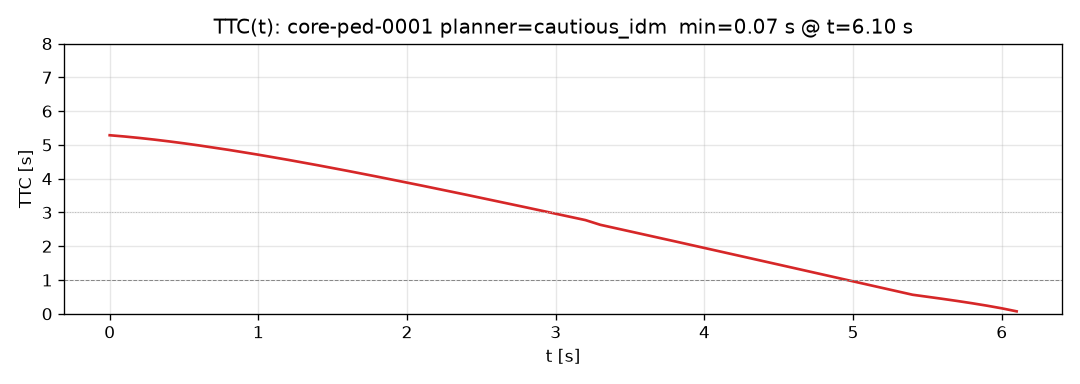
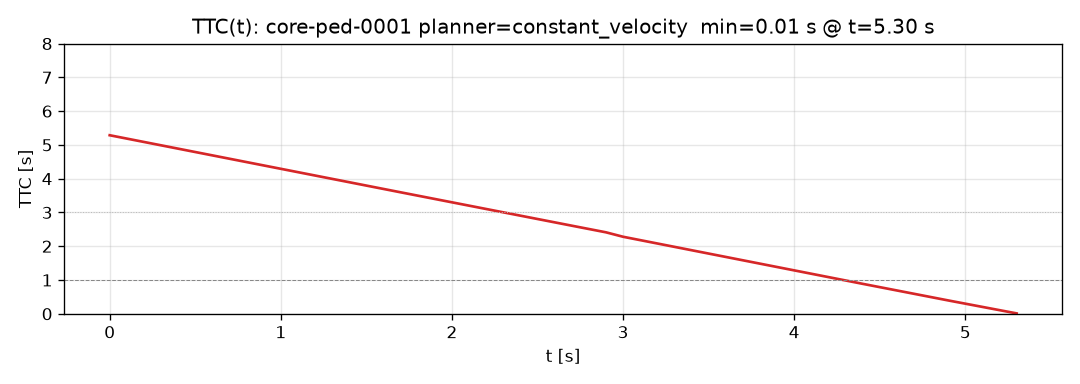
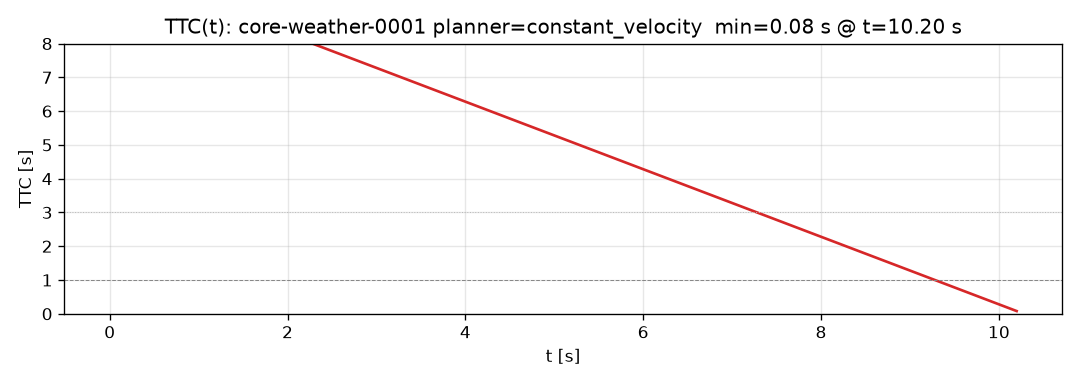
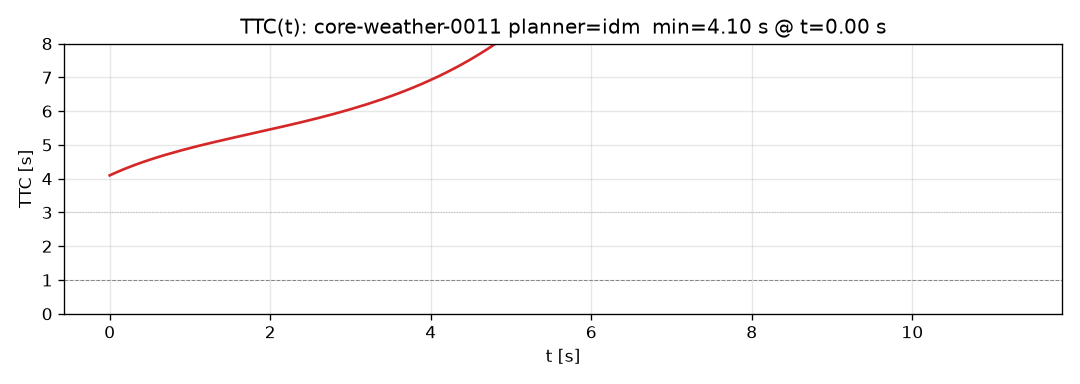
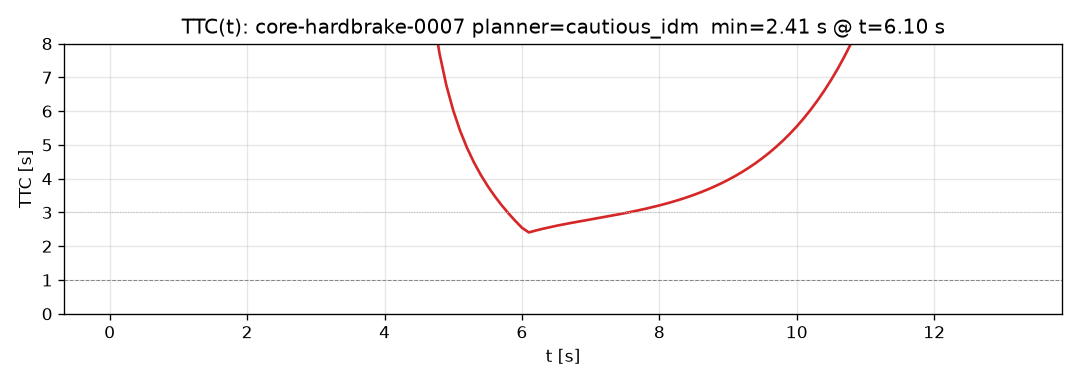
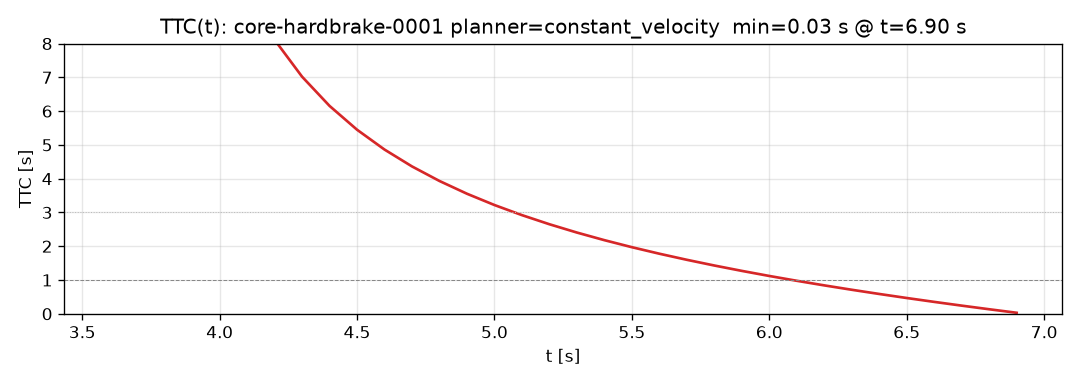
Time-to-Collision (minimum)
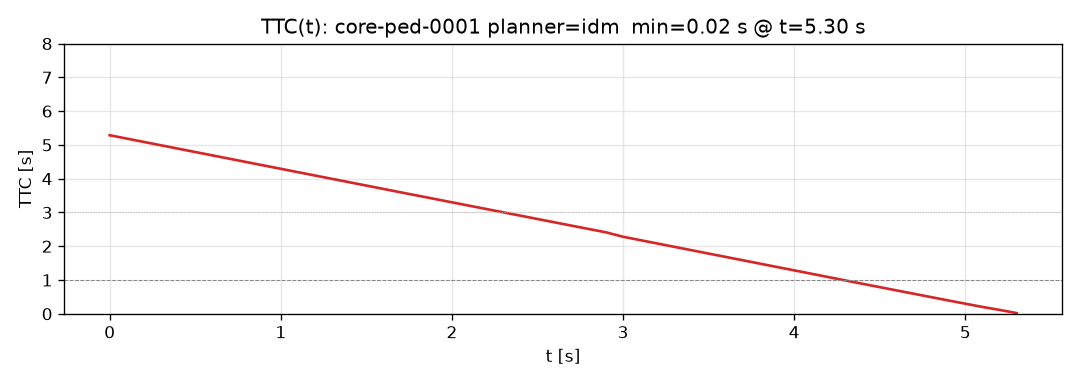
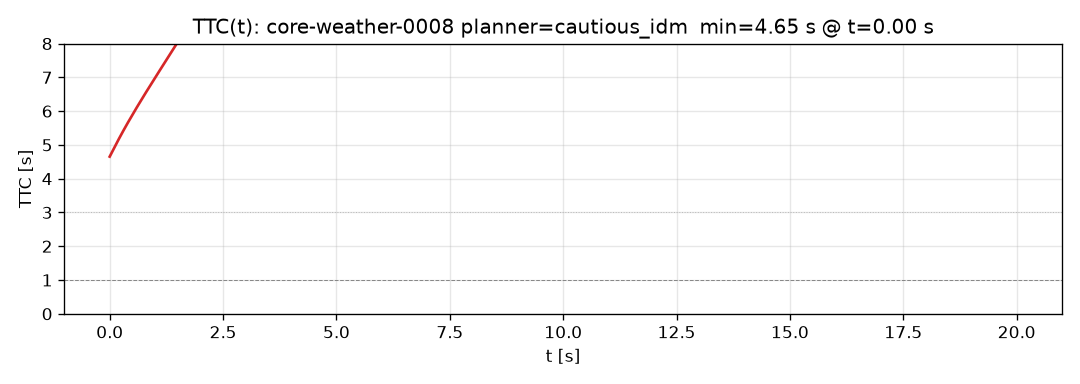
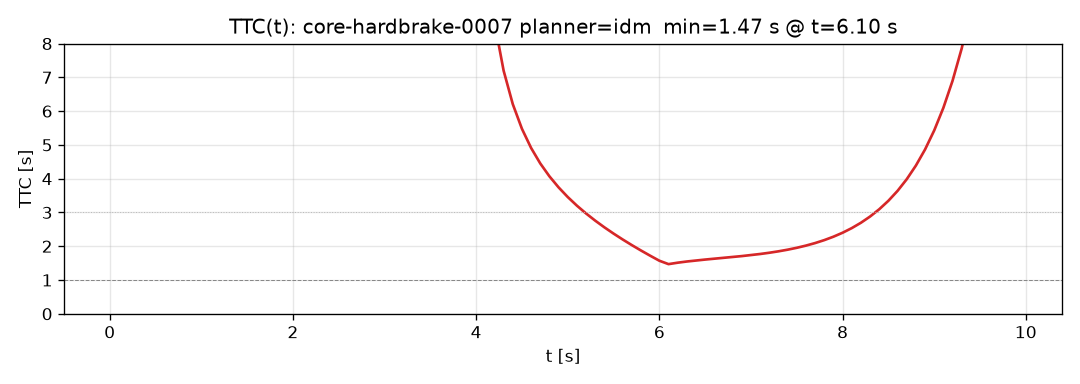
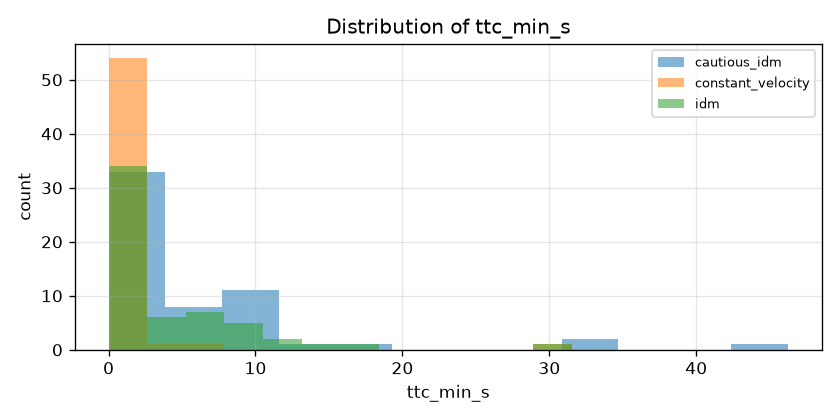
ttc_min_s |
metric |
ISO 21448:2022 (SOTIF) |
Clause 7; Annex C.2 |
Surrogate indicator for evaluation of known hazardous scenarios. |
| UL 4600:2023 |
Section 8 (Risk Assessment), 16 (Metrics & SPIs) |
Candidate safety performance indicator (SPI) with defined threshold. |
| EU AI Act (Reg. 2024/1689) |
Art. 9 (risk management), Art. 15 (accuracy & robustness) |
Quantitative evidence usable in a risk-management file. |
Post-Encroachment Time (minimum)
pet_min_s |
metric |
ISO 21448:2022 (SOTIF) |
Annex C.2 |
Complementary surrogate for conflict severity in shared conflict zones. |
| UL 4600:2023 |
Section 16 (Metrics & SPIs) |
Candidate SPI for spatiotemporal separation analysis. |
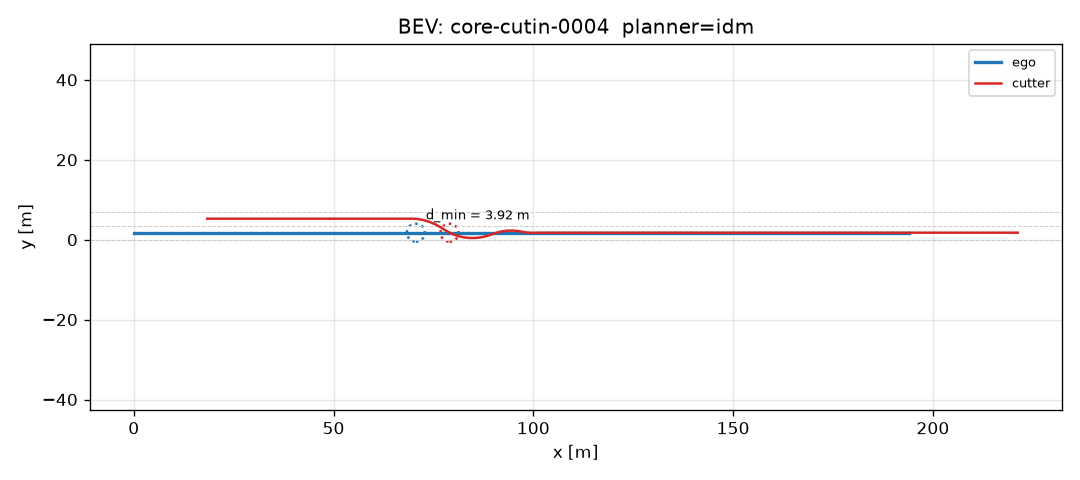
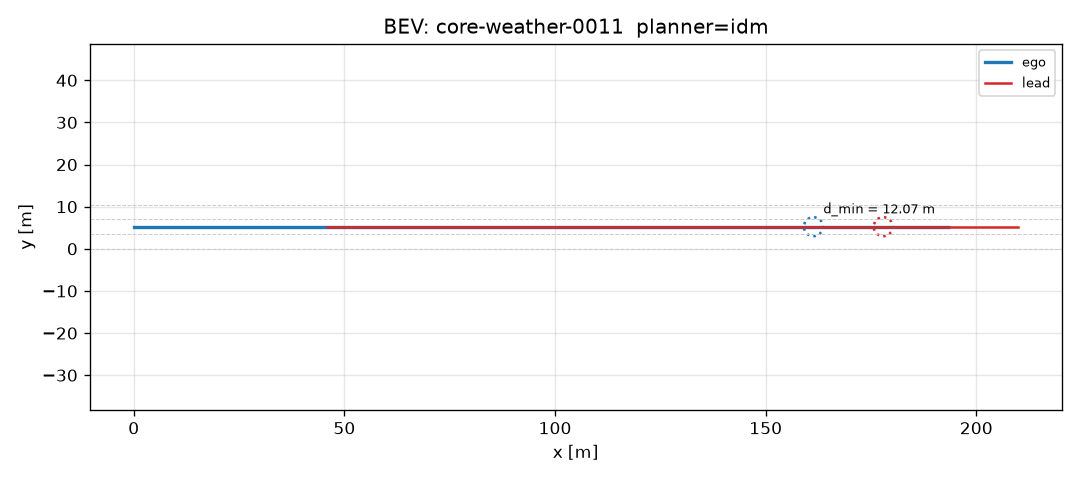
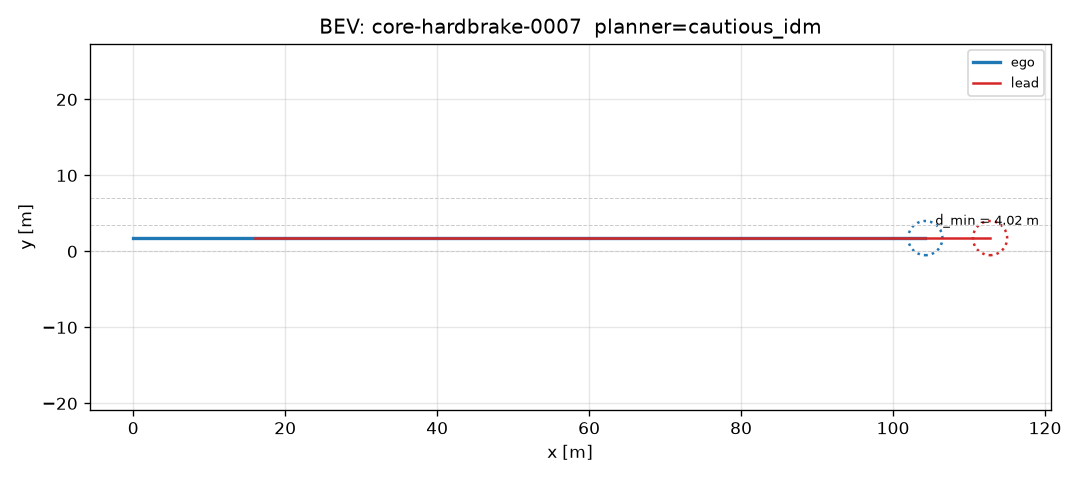
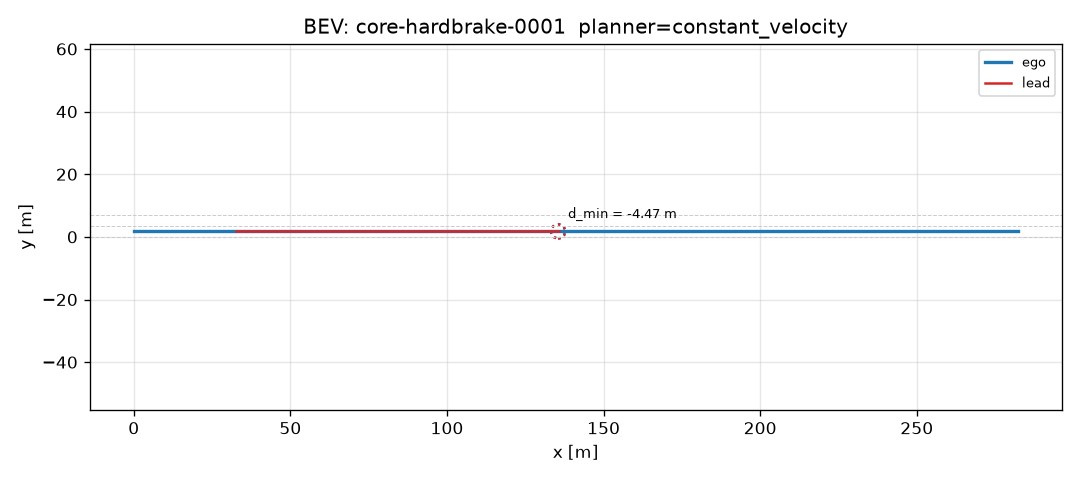
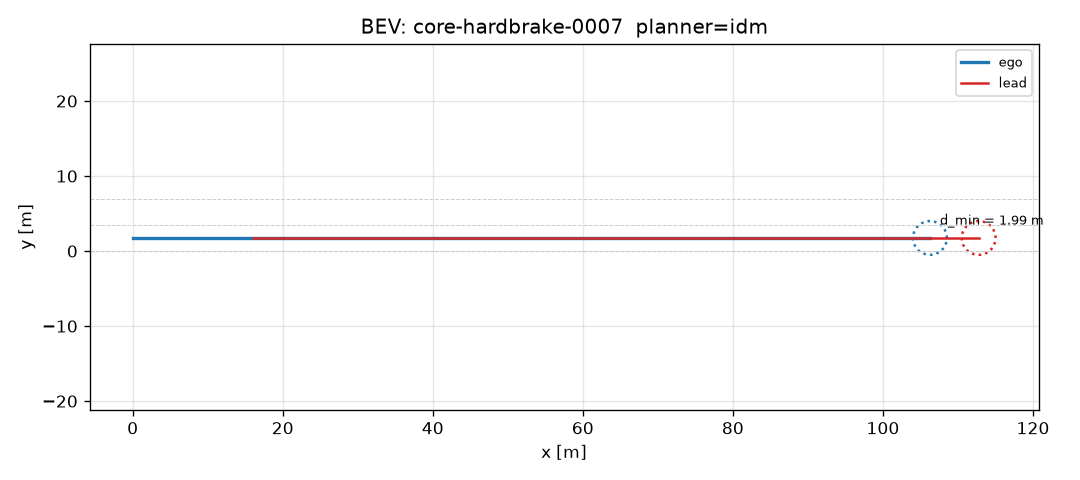
Minimum distance margin
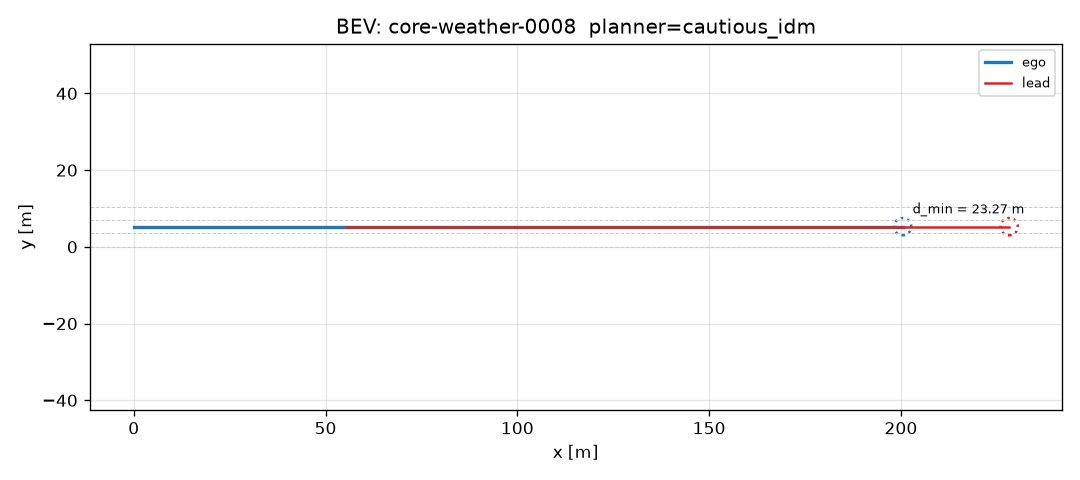
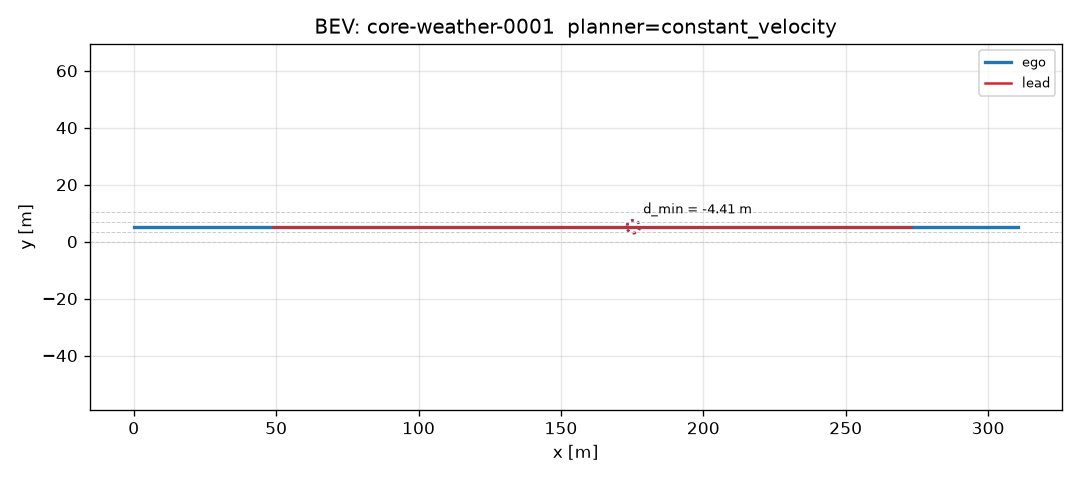
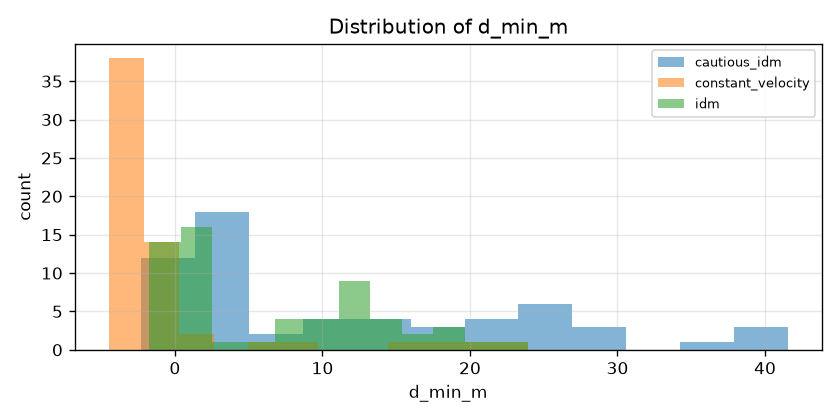
d_min_m |
metric |
ISO 21448:2022 (SOTIF) |
Clause 7.4; Annex C |
Direct measure of geometric safety margin under known scenarios. |
| UL 4600:2023 |
Section 8, 16 |
Distance-margin SPI usable as an acceptance-criterion input. |
Collision flag and delta-v severity
collision |
metric |
ISO 26262-3:2018 |
Clause 6 (HARA) |
Severity input dimension for hazard analysis and risk assessment. No ASIL is derived here. |
| ISO 21448:2022 (SOTIF) |
Clause 6; Annex F |
Terminal outcome metric for scenario evaluation. |
| UL 4600:2023 |
Section 8, 17 (Software & System Engineering) |
Loss-event and severity classification input. |
Hard-braking / intervention proxy
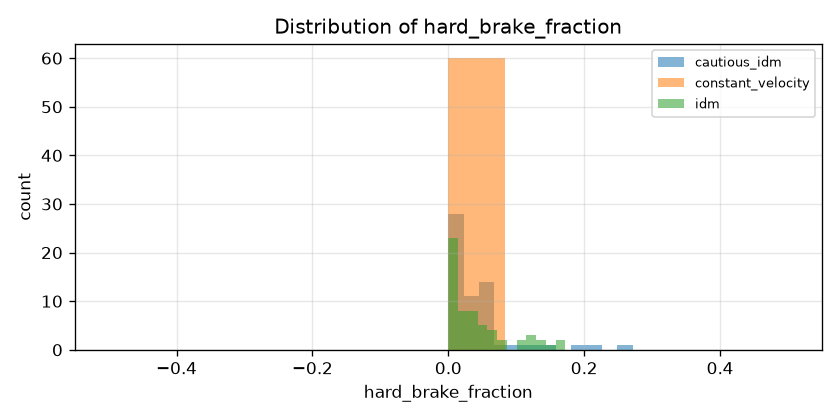
hard_brake_fraction |
metric |
UL 4600:2023 |
Section 16 (Metrics & SPIs) |
Operator-comfort and intervention SPI; -4 m/s^2 threshold from naturalistic-driving literature. |
| EU AI Act (Reg. 2024/1689) |
Art. 15 (robustness) |
Behavior-quality indicator informing robustness reporting. |
Aggressive cut-in scenario family
cut_in |
family |
ISO 21448:2022 (SOTIF) |
Clause 7.2; Annex F |
Known potentially hazardous scenario class; parameterized coverage. |
| ISO 26262-3:2018 |
Clause 6 (HARA inputs) |
Situation catalog input to hazard analysis. No ASIL is derived here. |
| UL 4600:2023 |
Section 8 (Risk Assessment) |
Operational-scenario coverage evidence. |
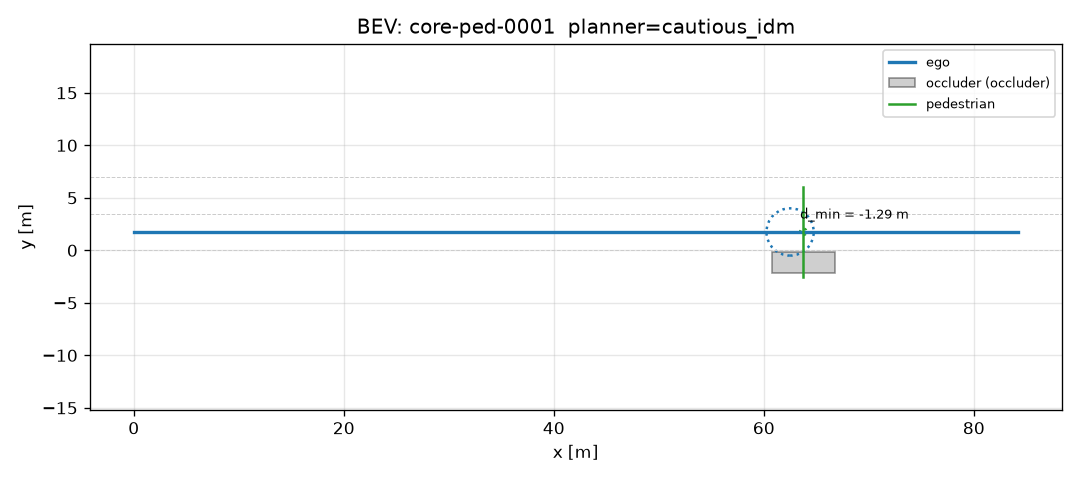
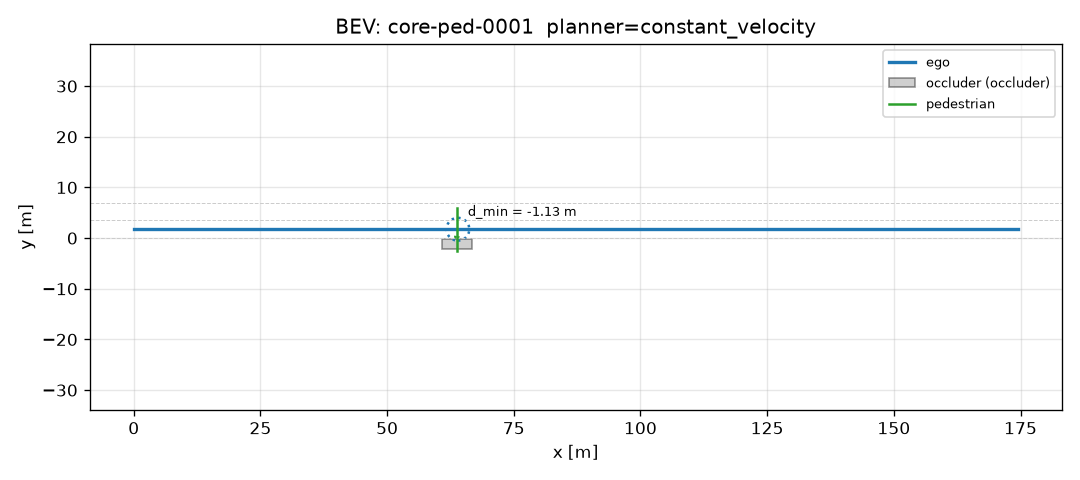
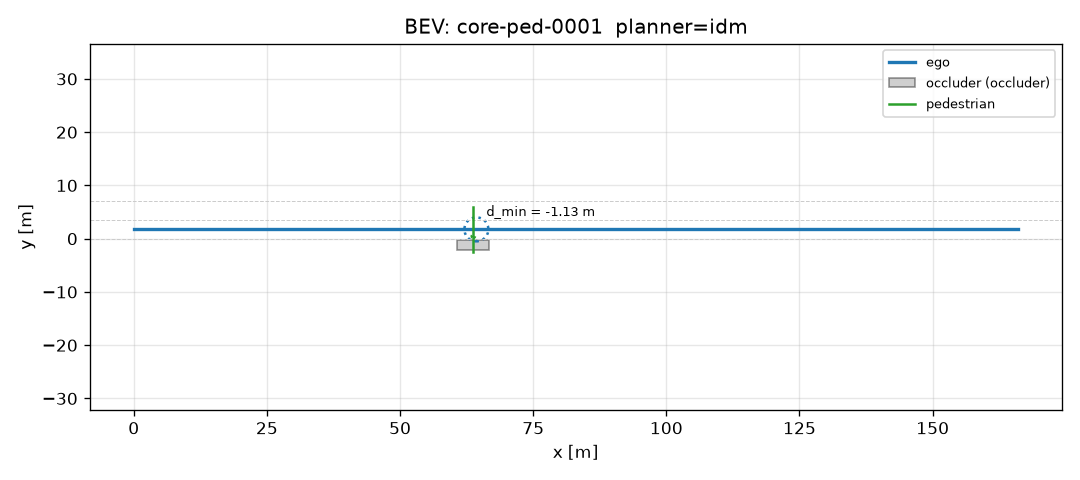
Occluded pedestrian emergence scenario family
ped_occluded |
family |
ISO 21448:2022 (SOTIF) |
Clauses 6 & 7; Annex F |
Vulnerable-road-user hazard class; occlusion is a canonical SOTIF trigger. |
| UL 4600:2023 |
Section 8, 17 |
Scenario-based assessment for pedestrian conflict. |
| EU AI Act (Reg. 2024/1689) |
Annex III (high-risk uses); Art. 9 |
Risk-management evidence for road safety-critical operation. |
ODD weather-degradation ramp scenario family
weather_ramp |
family |
ISO 21448:2022 (SOTIF) |
Clause 6 (ODD/triggering conditions) |
Explicit ODD-boundary and triggering-condition coverage. |
| UL 4600:2023 |
Section 8 (Risk Assessment) |
ODD-boundary evaluation informing autonomy assumptions. |
| EU AI Act (Reg. 2024/1689) |
Art. 10 (data governance), Art. 15 |
Robustness evaluation under environmental degradation. |
Lead-vehicle hard-brake scenario family
hard_brake |
family |
ISO 26262-4:2018 |
Clause 6 (System-level validation inputs) |
Longitudinal-conflict validation input. No ASIL is derived here. |
| ISO 21448:2022 (SOTIF) |
Clause 7; Annex F |
Known hazardous scenario class with parameter sweep. |
| UL 4600:2023 |
Section 8, 16 |
Longitudinal safety-envelope evaluation. |